 Sanjay OrugantiResearch Scientist · Rensselaer Polytechnic Institute
Research project · open-source robot hardware
HeRoSwarm
A miniature, fully capable swarm robot with open-source ROS support
- Published in
- IEEE/SICE Symposium on System Integration, 2023
- My part
- Mentor and co-author
- Where
- HeRo Lab, University of Georgia
- Open source
- Hardware designs and ROS software
Overview
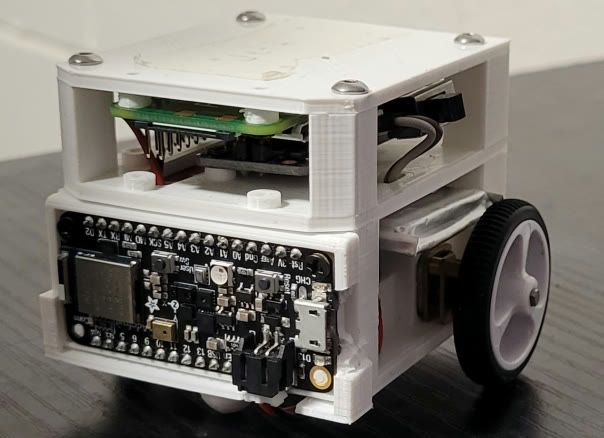
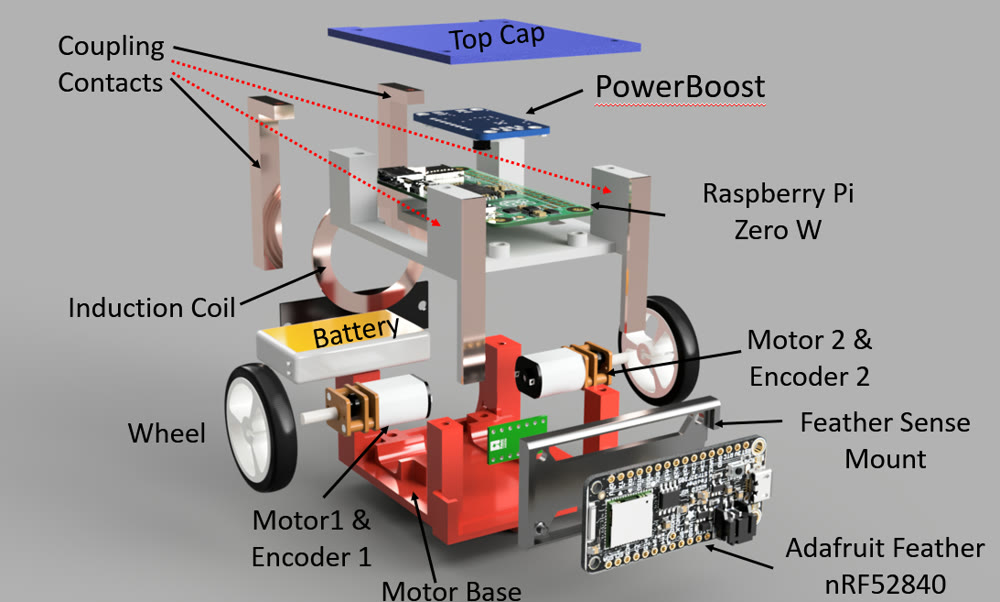
HeRoSwarm is a palm-sized robot built for experiments with many robots at once. It carries the sensing, computing and communication of a much larger robot, runs ROS, and its design files and software are open for other labs and classrooms to build.
What is on board
-
Sensing
Proximity, colour, sound, motion (IMU), altitude, humidity and pressure.
-
Computing
A Raspberry Pi Zero module that runs ROS on the robot itself.
-
Communication
Wi-Fi and Bluetooth, for talking to teammates and to a base station.
-
Motion and power
Two wheels with odometry, and inductive or magnetic charging.
Demos
-
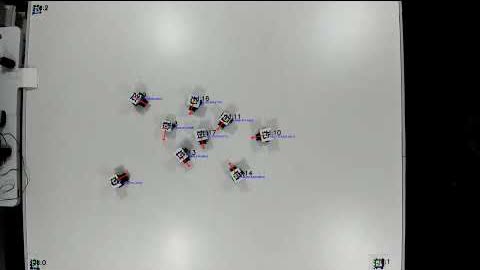 Rendezvous
The robots find each other and gather at one point.
-
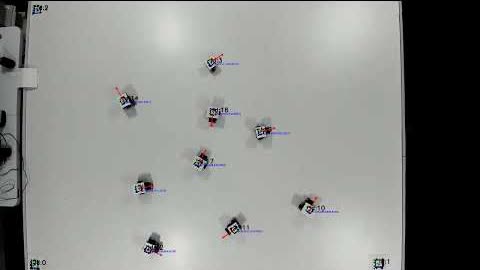 Formation control
The team arranges itself into a shape and holds it.
-
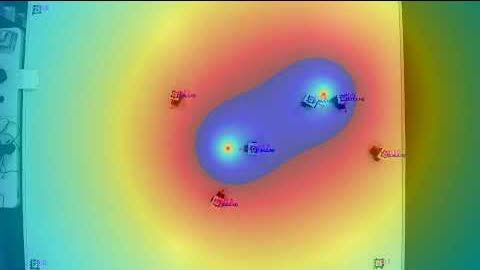 Coverage
The robots spread out to cover an area between them.
-
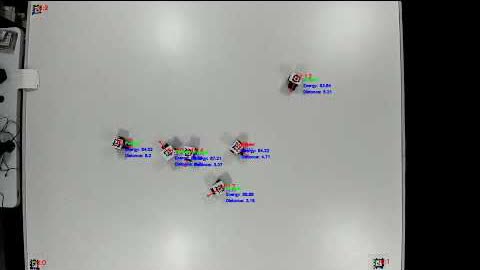 Pursuit and evasion
Some robots chase while others get away.
Videos by the HeRo Lab, on YouTube.
My role
I mentored the two student authors during my Ph.D. One of them joined the lab while still in high school. I asked him to design the chassis of a small swarm robot; soon he had moved on to its control and odometry, and before he finished school he was a co-author of this paper.
Explore further
Paper and code
Cite
SII 2023
HeRoSwarm: Fully-capable miniature swarm robot hardware design with open-source ROS support
2023 IEEE/SICE International Symposium on System Integration (SII), Atlanta, GA, USA, pp. 1–7 (2023).
BibTeX
@inproceedings{starks2023heroswarm,
  author = {Starks, M. and Gupta, A. and Oruganti, S. and Parasuraman, R.},
  title = {HeRoSwarm: Fully-capable miniature swarm robot hardware design with open-source ROS support},
  booktitle = {2023 IEEE/SICE International Symposium on System Integration (SII)},
  pages = {1--7},
  address = {Atlanta, GA, USA},
  year = {2023}
}