 Sanjay OrugantiResearch Scientist · Rensselaer Polytechnic Institute
Research project · multi-robot systems
KT-BT
Robots that teach each other new behaviors during a mission
- Published in
- IEEE Transactions on Robotics, 2023
- Presented at
- ICRA 2024, Yokohama
- My part
- First author; part of my Ph.D.
- Where
- HeRo Lab and DICE Lab, University of Georgia
Overview
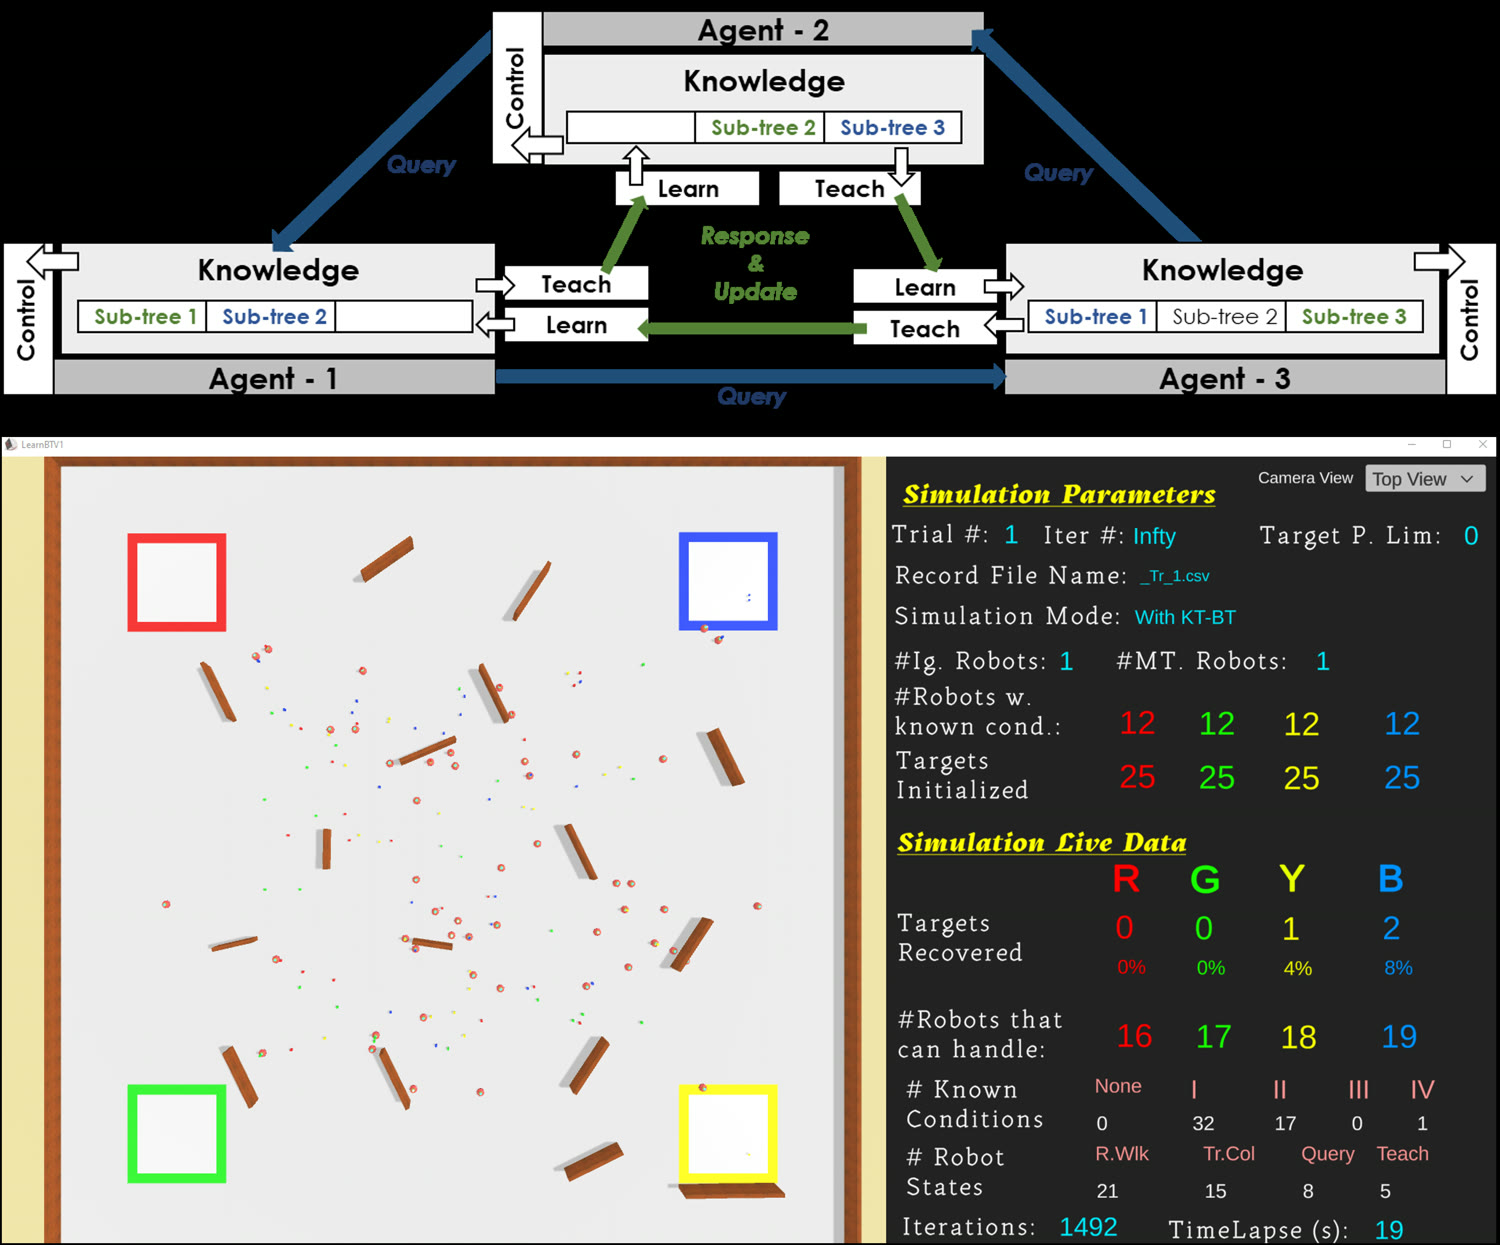
In a team of unlike robots, no robot knows how to handle everything. KT-BT (knowledge transfer through behavior trees) lets a robot that meets a situation it cannot handle ask its teammates, receive the missing piece of behavior, and add it to its own behavior tree while the mission is still running.
Framework
Mechanism
Query, response, update
A robot that meets an unknown condition queries its neighbors; a robot that knows the answer responds, and the asker updates its own behavior tree online.
Representation
stringBT grammar
A grammar structure that encodes knowledge as behavior sub-trees, so that behaviors can be shared efficiently between agents.
Evaluation
Search and rescue
Extensive simulations show successful knowledge transfers and improved group performance, and examine how communication range and opportunities affect knowledge spread and functional heterogeneity.
Explore further
Paper and code
Related work
- On this site IKT-BT The follow-up: robots learn by overhearing their teammates instead of asking. Project page →
- Paper Doctoral dissertation Exploiting Emergence, Heterogeneity, and Knowledge Transfer in Multi-Agent Systems. University of Georgia ↗
- Video Impact of heterogeneity in multi-robot systems The study that led here: how differences between robots change a search-and-rescue mission. SSRR 2020. HeRo Lab on YouTube ↗
- Paper Heterogeneity paper The SSRR 2020 paper behind that video. arXiv ↗
- Lab HeRo Lab Heterogeneous Robotics Research Lab, where the multi-robot work was done. herolab.org ↗
- Lab DICE Lab Design Informatics and Computational Engineering Lab, College of Engineering. University of Georgia ↗
Cite
IEEE T-ROAlso presented at ICRA 2024, Yokohama, Japan
KT-BT: A framework for knowledge transfer through behavior trees in multirobot systems
IEEE Transactions on Robotics, 1–17 (2023).
BibTeX
@article{oruganti2023framework,
  author = {Oruganti, S. and Parasuraman, R. and Pidaparti, R.},
  title = {KT-BT: A framework for knowledge transfer through behavior trees in multirobot systems},
  journal = {IEEE Transactions on Robotics},
  pages = {1--17},
  year = {2023},
  doi = {10.1109/TRO.2023.3290449}
}